
Depth Estimation
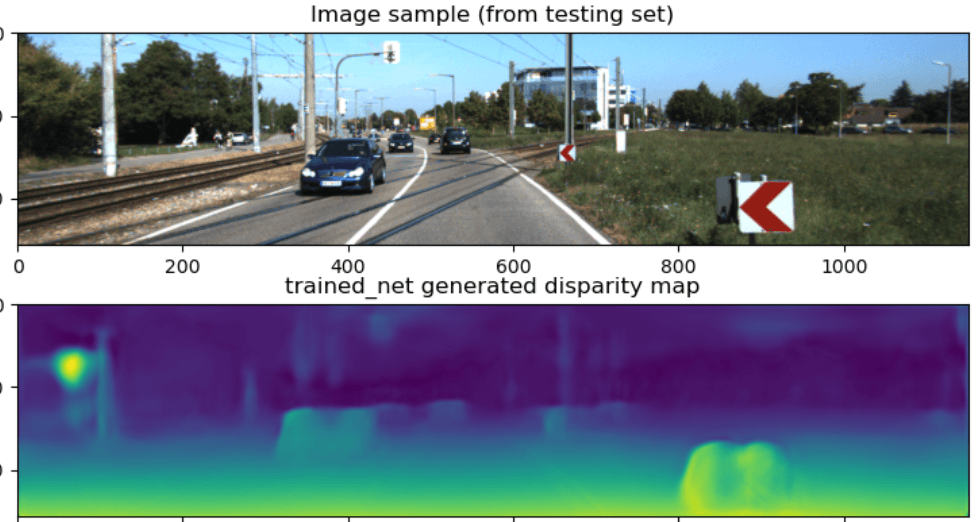


Description
As the final project for my CS 484 Computational Vision course, we created a convolutional neural network capable of estimating a depth map in driving scenarios. What was most interesting about this project was that we were able to leverage the geometry of the problem to enable unsupervised learning. This is because the dataset featured left and right images taken by two cameras for each scene, so the network learned to produce pixel-wise disparity maps, which are correlated to the distance of the corresponding object. We followed some papers and produced a report, which is partly available in the GitHub link.